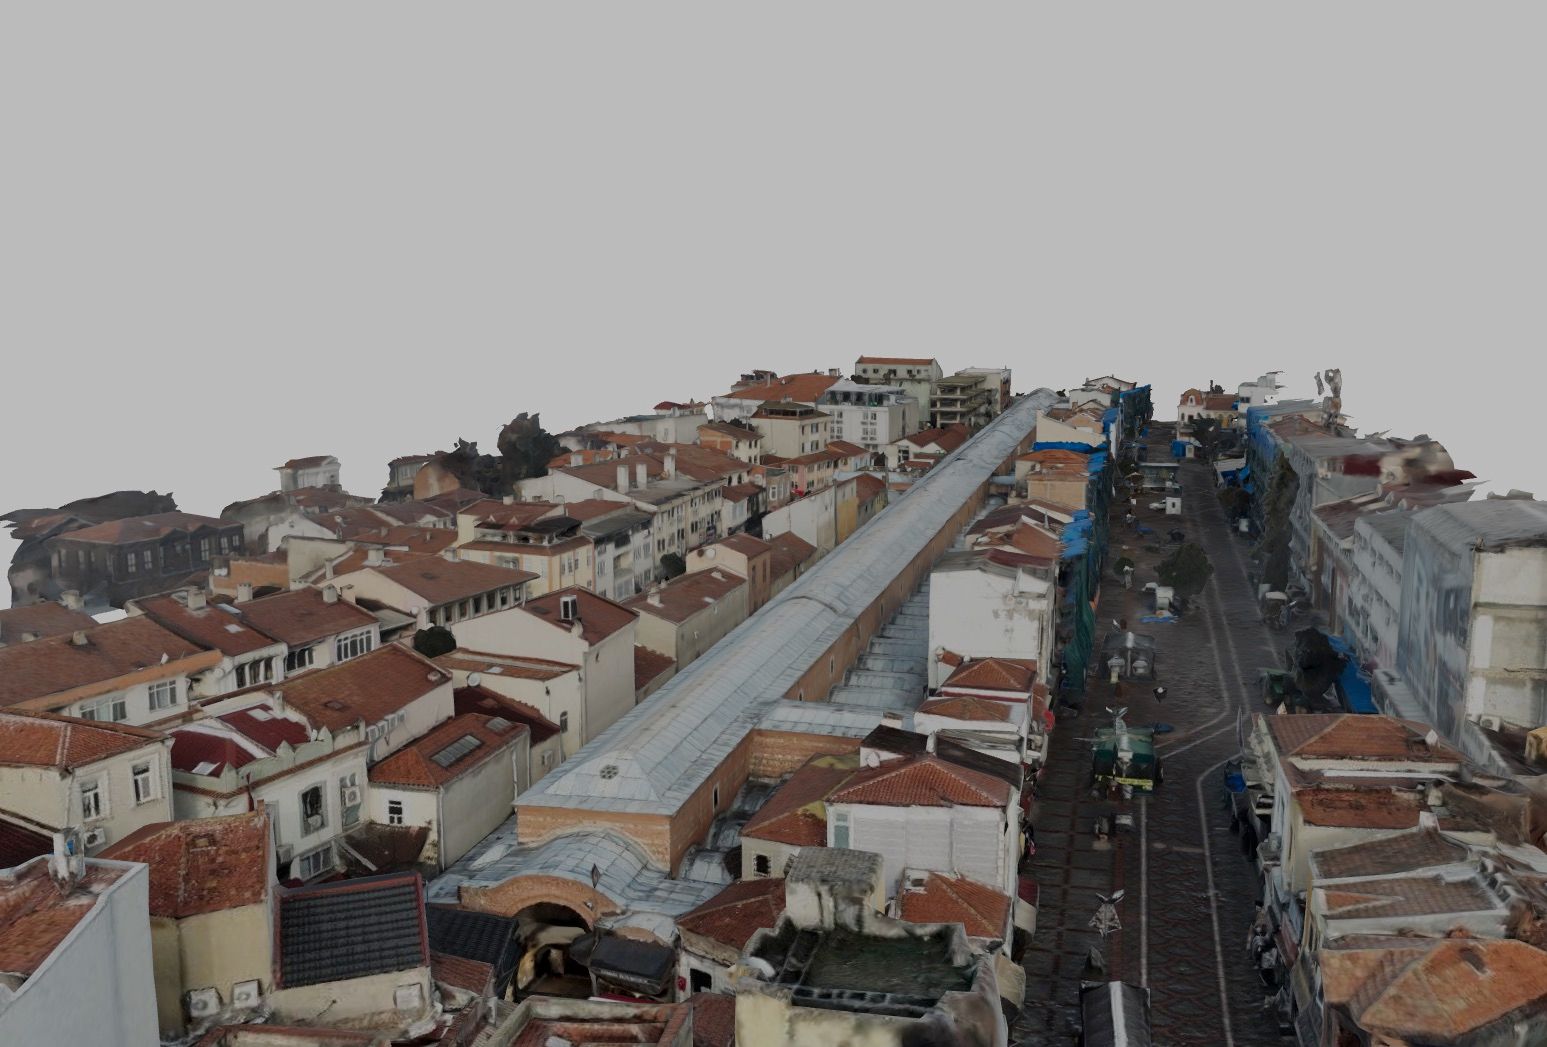
 1,122 photos
Edirne, Türkiye
Selimiye Mosque and Selimiye Arasta Bazaar
Selimiye Camii ve Selimiye Arasta Çarşısı
DJI Mini 3 + DJI Mini 4 Pro · Jan 2025
Multi-View Photogrammetry Dataset
An open multi-view architectural dataset containing 10,594 high-resolution photographs across 20 diverse historic and modern structures (~75 GB across 6 countries). Each structure is captured within an under-1-hour window to minimize solar drift, and ships with COLMAP Structure-from-Motion camera poses and reference photogrammetric OBJ and PLY meshes for 3D Gaussian Splatting, NeRF, and cultural heritage reconstruction research.
Complete Scene Index
Every building pairs its canonical FUNES 3D archive page with its per-scene Google Drive .zip download containing raw photographs, COLMAP sparse poses, and reference meshes.
1,122 photosEdirne, Türkiye
Selimiye Camii ve Selimiye Arasta Çarşısı
DJI Mini 3 + DJI Mini 4 Pro · Jan 2025
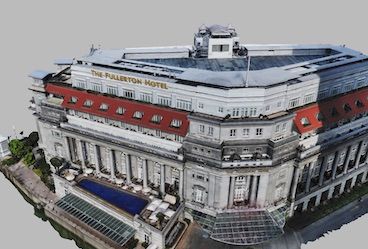 1,981 photos
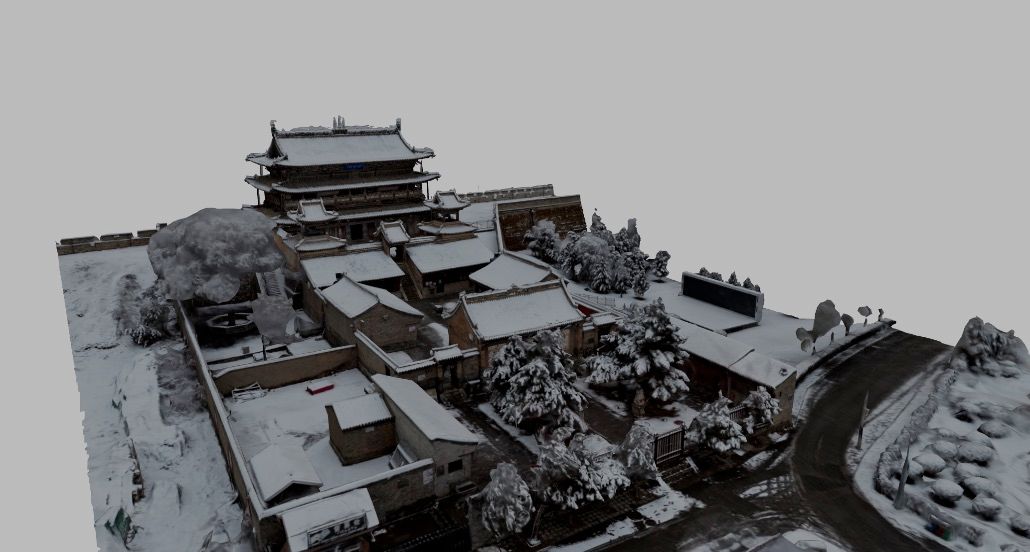 1,433 photos
 704 photos
 1,054 photos
 728 photos
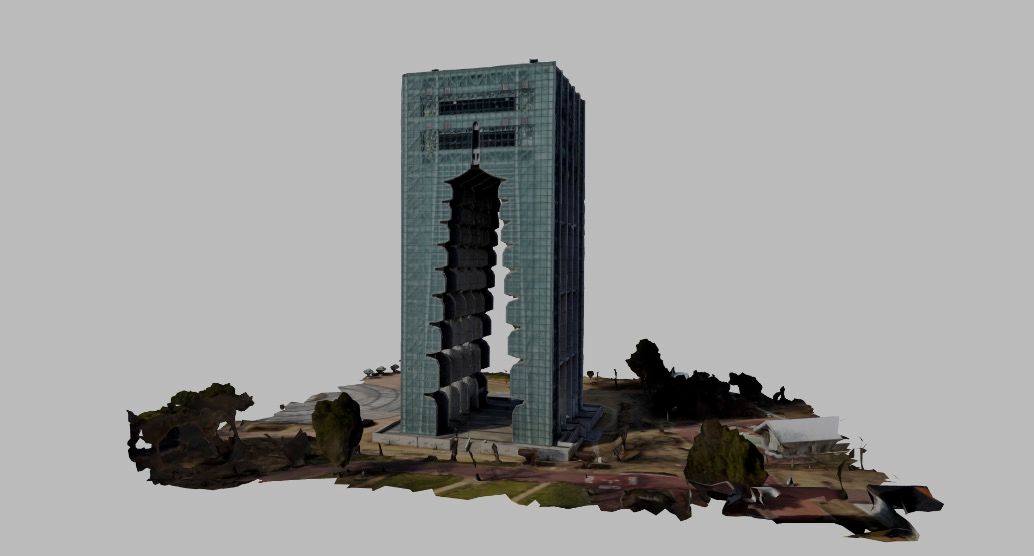 706 photos
 442 photos
California, United States
DJI Mini 4 Pro · Dec 2024 · Drive: Rocks Near A Beach
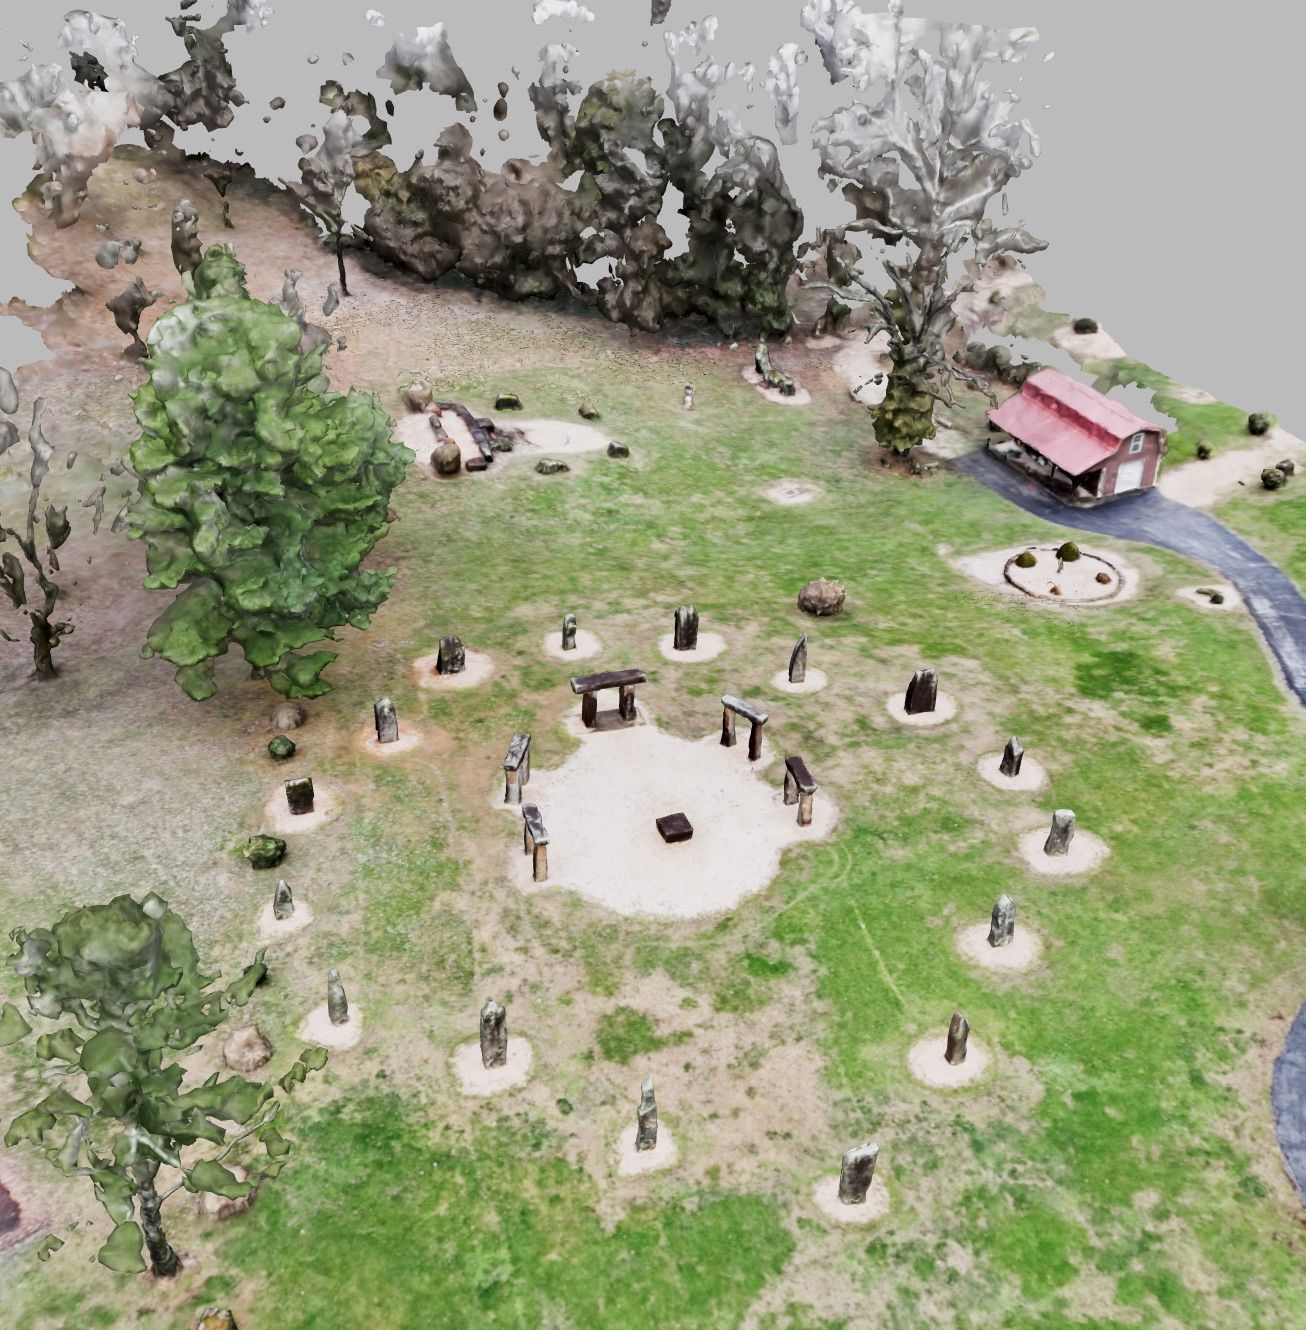 387 photos
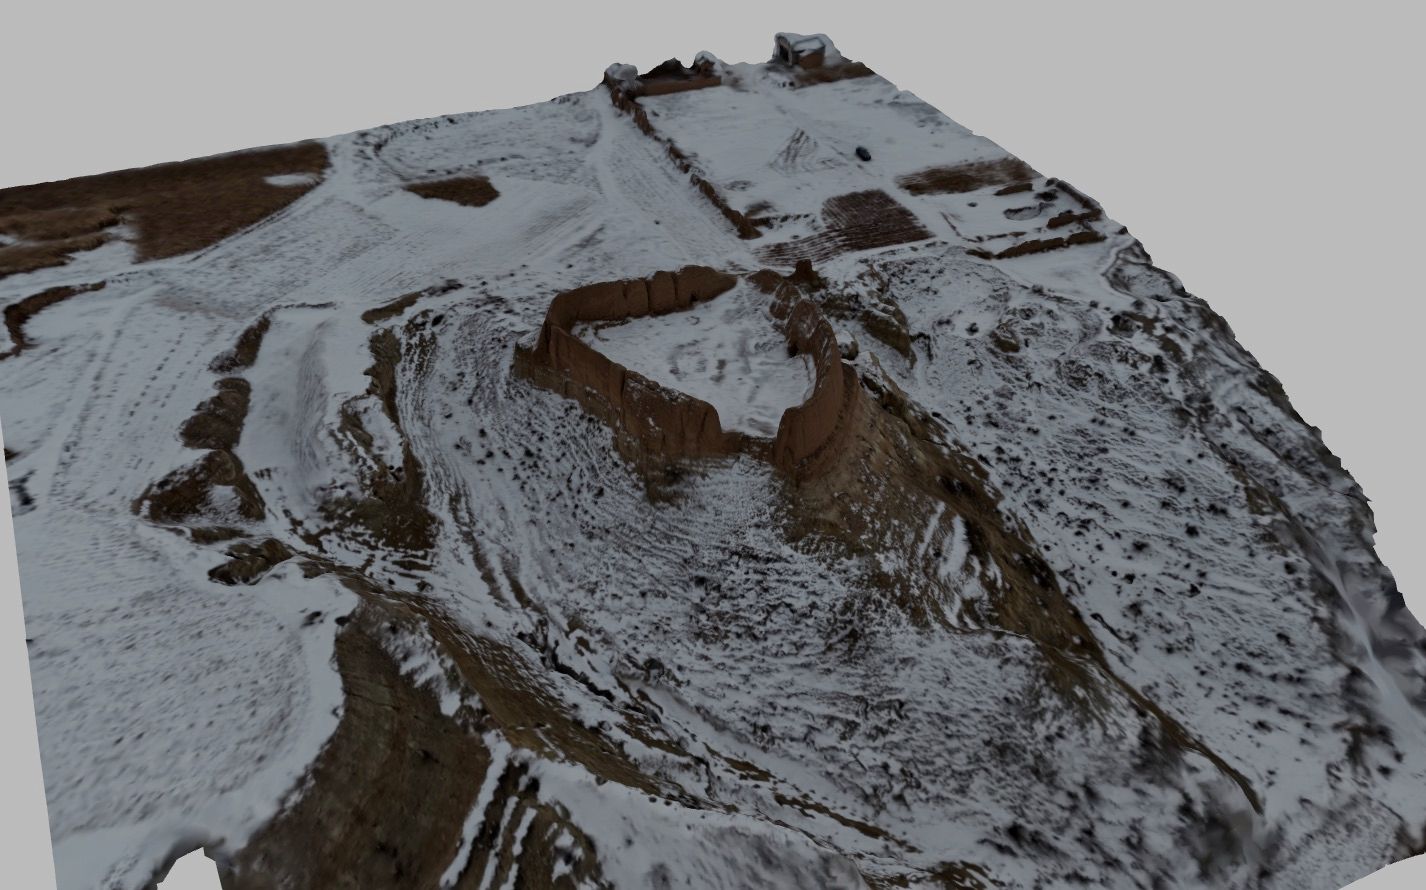 380 photos
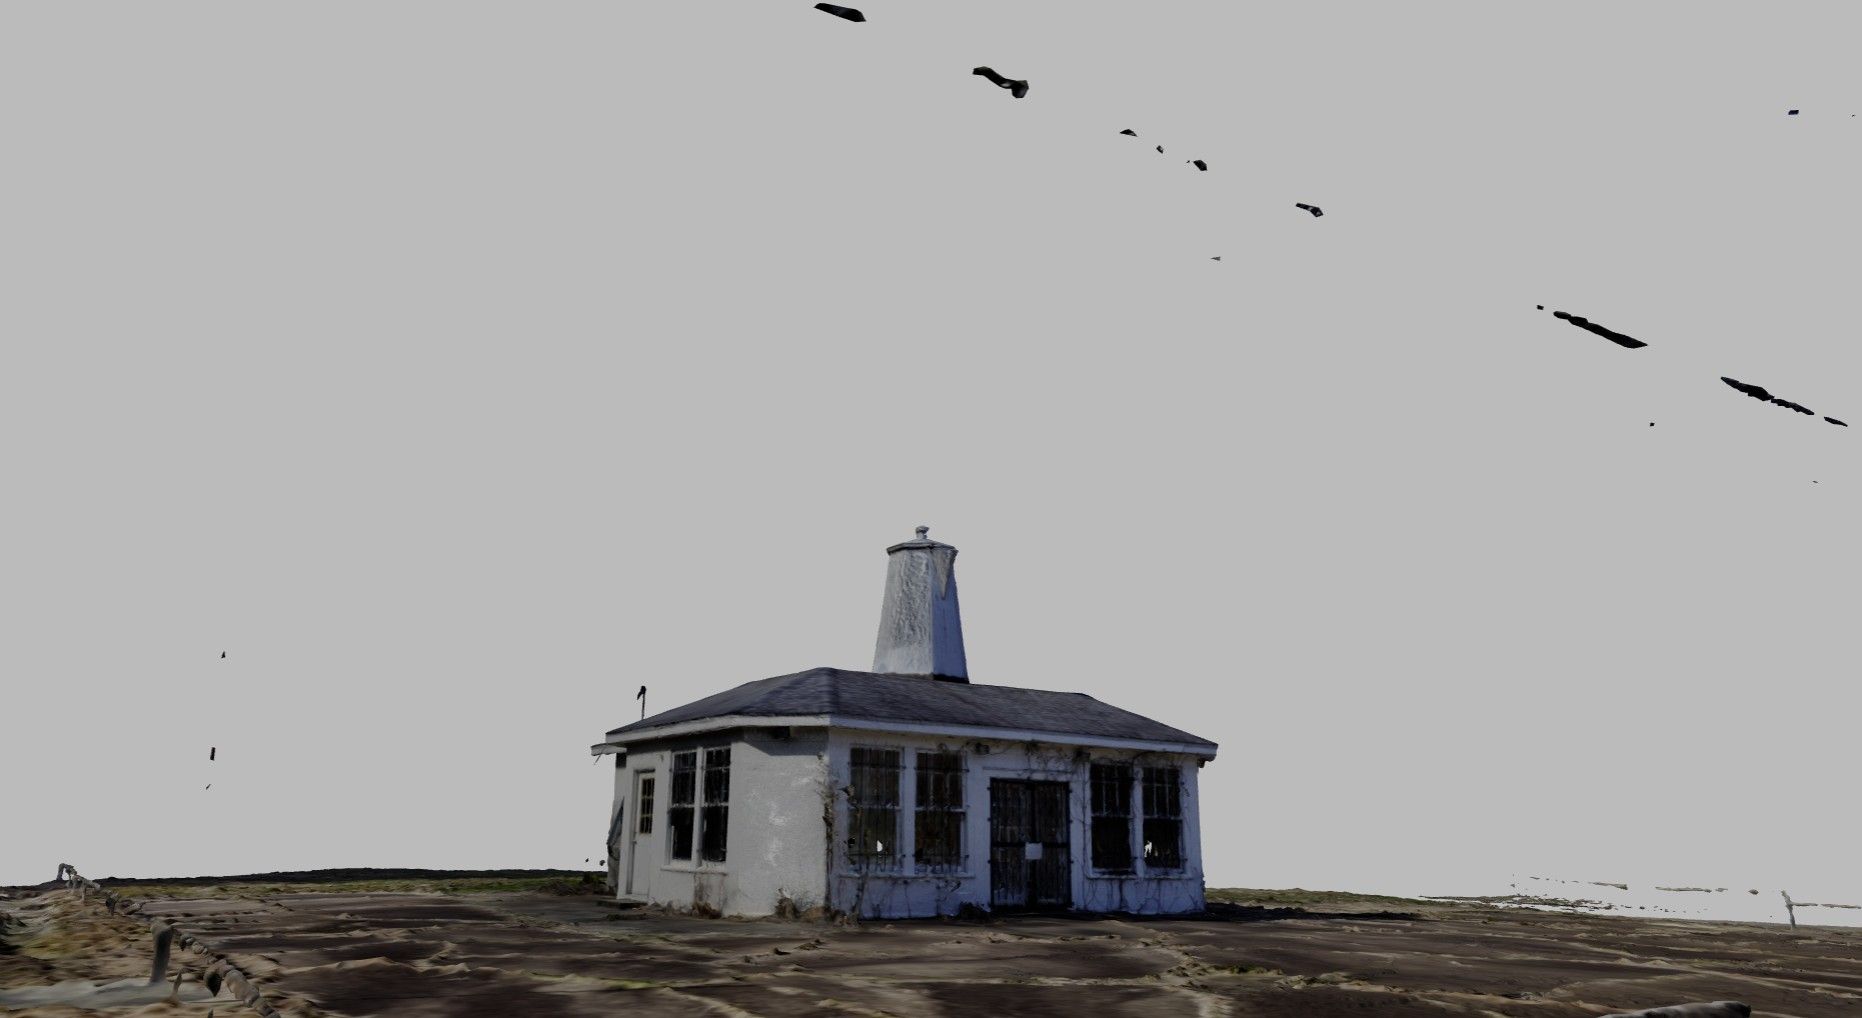 269 photos
 255 photos
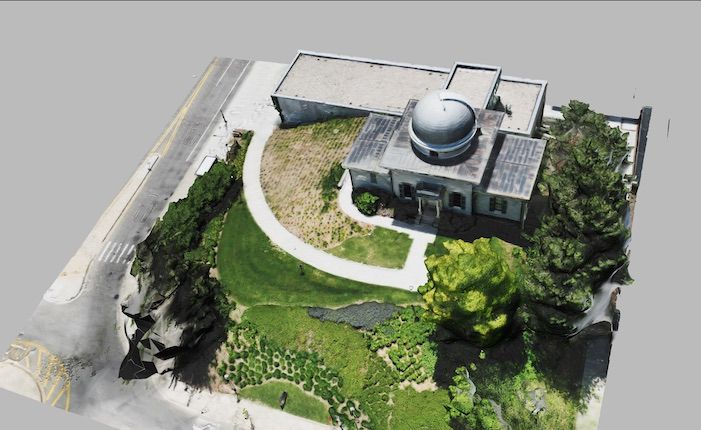 217 photos
 184 photos
 174 photos
 171 photos
 151 photos
 99 photos
 78 photos
 59 photos
Verified layout inside each extracted scene archive on Google Drive. Run colmap model_analyzer to inspect per-sensor intrinsics before training.
FUNES Open 3D Architecture Dataset/
├── _README.txt
├── _licence.txt
├── dataset specs.pdf
├── <Building>/
│   ├── <Scene>.txt    # Scene notes
│   ├── images/        # Full-res .jpg photos
│   ├── sparse/0/      # COLMAP SfM .bin files
│   ├── models/OBJ/    # Reference .obj mesh
│   └── models/PLY/    # Reference .ply mesh
└── <Building>.zip     # 20 building archives
Recommended sanity check: colmap model_analyzer --path ./<Building Name>/sparse/0
Switch between BibTeX, APA, and RIS formats to cite this resource in publications or reference managers.
@misc{FUNES_open_3d_architecture_2026,
  author       = {FUNES.WORLD Research Team},
  title        = {{FUNES Open 3D Architecture Dataset}},
  year         = {2026},
  publisher    = {FUNES.WORLD},
  version      = {1.0},
  url          = {https://funes.world/datasets/open-3d-architecture},
  note         = {License: CC BY-NC 4.0; Repository: https://drive.google.com/drive/folders/1YGBLjINI2JPrpAE3iCDpxER6agJtC6lq?usp=sharing}
}
Technical Reference
Practical guidance on coordinate conventions, evaluation protocols, file conversion, and licensing boundaries.
Nine of the 20 scenes combine distinct sensors—such as Sony mirrorless cameras or iPhones paired with DJI Mini 3, Mini 4 Pro, or Air 3S drones (or dual-drone captures like Selimiye Mosque and Ali Pasha Bazaar)—so sparse/0/cameras.bin stores per-sensor intrinsics and distortion parameters rather than assuming a single shared lens. Because standard 3D Gaussian Splatting rasterizers require distortion-free pinhole projection, inspect cameras.bin with colmap model_analyzer and run colmap image_undistorter if your trainer assumes zero-distortion pinhole frames, while accounting for minor white-balance or exposure differences between ground and aerial shots even within under-1-hour captures.
The archive ships full-scene images/ and sparse/0/ reconstructions without a baked-in split JSON or official PSNR, SSIM, and LPIPS leaderboard. To keep novel view synthesis comparisons reproducible, follow established real-world conventions such as Mip-NeRF 360 deterministic every-8th-frame holdout (llffhold=8) and state explicitly whether held-out frames span both aerial and ground sensors on mixed captures like Fullerton Hotel or Yuhuang Pavilion; note also that no pre-generated sky, pedestrian, or transient masks are included.
No. The meshes in models/OBJ/ and models/PLY/ are photogrammetric reconstructions derived from the multi-view photographs rather than independent terrestrial laser scanning (LiDAR) ground truth, and COLMAP sparse/0/ poses carry arbitrary Structure-from-Motion scale unless aligned to known architectural dimensions. Treat the meshes as qualitative surface references or coarse geometric priors rather than sub-millimeter laser-scan ground truth in Chamfer Distance or F-score benchmarks.
Yes. On the official Google Drive repository, all 20 structures (10,594 high-resolution .jpg photographs captured between June 2024 and March 2025 across China, South Korea, Singapore, Japan, Türkiye, and the United States) are browsable and downloadable per building as individual .zip archives alongside _README.txt, _licence.txt, and dataset specs.pdf. After extracting a scene, verify that images/, sparse/0/ (cameras.bin, images.bin, points3D.bin), models/OBJ/, and models/PLY/ are complete before training.
Under Creative Commons Attribution-NonCommercial 4.0 International (CC BY-NC 4.0), academic labs and independent researchers may freely download, modify, train models, and publish benchmark papers or figures using the photographs and reconstructions with attribution to FUNES.WORLD. However, training commercial foundation models, integrating the scenes into paid software products, or deploying derived reconstructions for commercial advantage requires separate written permission from FUNES.